TRAIN: Terrain-Aware Interactive Navigation for Quadruped Robots via Reinforcement Learning
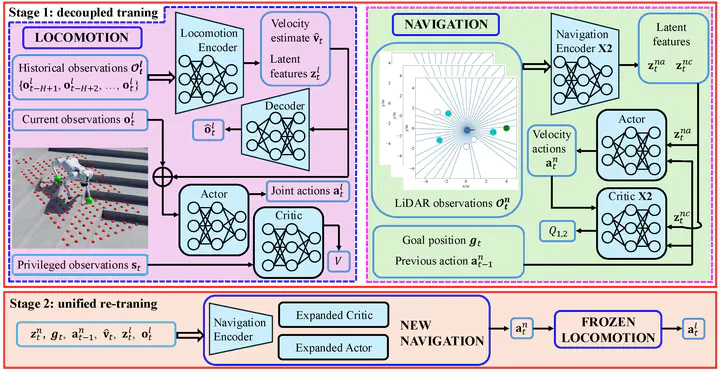 Image credit: Unsplash
Abstract
This study introduces TRAIN – TeRrain-Aware Interactive Navigation, a deep reinforcement learning (DRL)-based framework for quadrupedal navigation across unstructured terrain and human-populated environments. Conventional quadrupedal navigation typically separates motion planning from locomotion control, neglecting whole-body constraints and terrain awareness. On the other hand, end-to-end methods are more integrated but require high-frequency sensing, which is often noisy and computationally costly. In addition, most existing approaches assume static environments, limiting their use in human-populated settings. To address these limitations, we propose a two-stage training framework with three DRL pipelines. (1) TRAIN-Loco employs an asymmetric actor–critic (AC) model for quadrupedal locomotion, enabling agile traversal of uneven terrains without explicit terrain or contact observations. (2) TRAIN-Nav applies a symmetric AC framework for navigation with interactive pedestrians, directly mapping transformed LiDAR data to ego-agent actions under differential-drive kinematics. (3) A unified pipeline, TRAIN, integrates TRAIN-Loc and TRAIN-Nav, supporting terrain-aware quadrupedal navigation in uneven and interactive environments. Comprehensive benchmarks against quadrupedal locomotion and robot navigation baselines demonstrate the effectiveness of TRAIN. Hardware experiments further confirm its potential for sim-to-real transfer.
Wei Zhu
Assistant Professor
My research interests include deep reinforcement learning, snake robots, wheeled bipedal robots, robotic arms, quadruped robots, humanoid robots, and social navigation.