Wei Zhu
Wei Zhu
Home
Publications
Contact
2
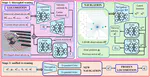
TRAIN: Terrain-Aware Interactive Navigation for Quadruped Robots via Reinforcement Learning
Wei Zhu
,
Irfan Tito Kurniawan
,
Ye Zhao
,
and Mitsuhiro Hayashibe
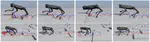
Synergy of Postural Adaptation and Exteroception for Robust CPG-driven Quadrupedal Locomotion
Irfan Tito Kurniawan
,
Wei Zhu
,
Dai Owaki
,
and Mitsuhiro Hayashibe
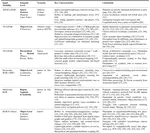
A Systematic Review of Robot Topological Semantic Mapping and Localization for Spatial Understanding
Feroz Fernando
,
Wei Zhu
,
Atsushi Yamashita
,
and Mitsuhiro Hayashibe
Iterative Adversarial Learning with Chaser Agents for Time-efficient Crowd-aware Navigation
Tianjian Yuan
,
Wei Zhu
,
Mitsuhiro Hayashibe
EmoBipedNav: Emotion-aware Social Navigation for Bipedal Robots with Deep Reinforcement Learning
Wei Zhu
,
Abirath Raju
,
Abdulaziz Shamsah
,
Anqi Wu
,
Seth Hutchinson
,
and Ye Zhao
Learning Perceptive Legged Robot Locomotion in the Real World A Systematic Review
Irfan Tito Kurniawan
,
Wei Zhu
,
Dai Owaki
,
and Mitsuhiro Hayashibe
Spatiotemporal Feature-Encoded Navigation for USVs in Unpredictable Maritime Scenarios
Zhiting Yao
,
Xiyuan Chen
,
Mitsuhiro Hayashibe
,
Ninghui Xu
,
Tianjian Yuan
,
Wei Zhu
Local Collision Avoidance for Unmanned Surface Vehicles based on an End-to-End Planner with a LiDAR Beam Map
Zhiting Yao
,
Xiyuan Chen
,
Mitsuhiro Hayashibe
,
Wei Zhu
,
and Ninghui Xu
Learn to Teach: Sample-Efficient Privileged Learning for Humanoid Locomotion Over Real-World Uneven Terrain
Feiyang Wu
,
Xavier Nal
,
Jaehwi Jang
,
Wei Zhu
,
Zhaoyuan Gu
,
Anqi Wu
,
and Ye Zhao
Autonomous Navigation System in Pedestrian Scenarios using a Dreamer based Motion Planner
Wei Zhu
,
and Mitsuhiro Hayashibe
»
Cite
×